Repository Details
Shared by
HelloGitHub Rating
0 ratings
Desktop Open-Source Dual-Wheel Legged Robot
Past 6 days Received 16 stars ✨
Use arrow keys to explore dates, Home and End for the first and last date, Escape to dismiss.| Date | Star | Daily change |
|---|---|---|
| 周日 | 3,827 | — |
| 周一 | 3,833 | +6 |
| 周二 | 3,835 | +2 |
| 周三 | 3,839 | +4 |
| 周四 | 3,840 | +1 |
| 周五 | 3,843 | +3 |
3.8k
Stars
Yes
Chinese
C++
Language
No
Active
2
Contributors
12
Issues
No
Organization
None
Latest
589
Forks
None
License
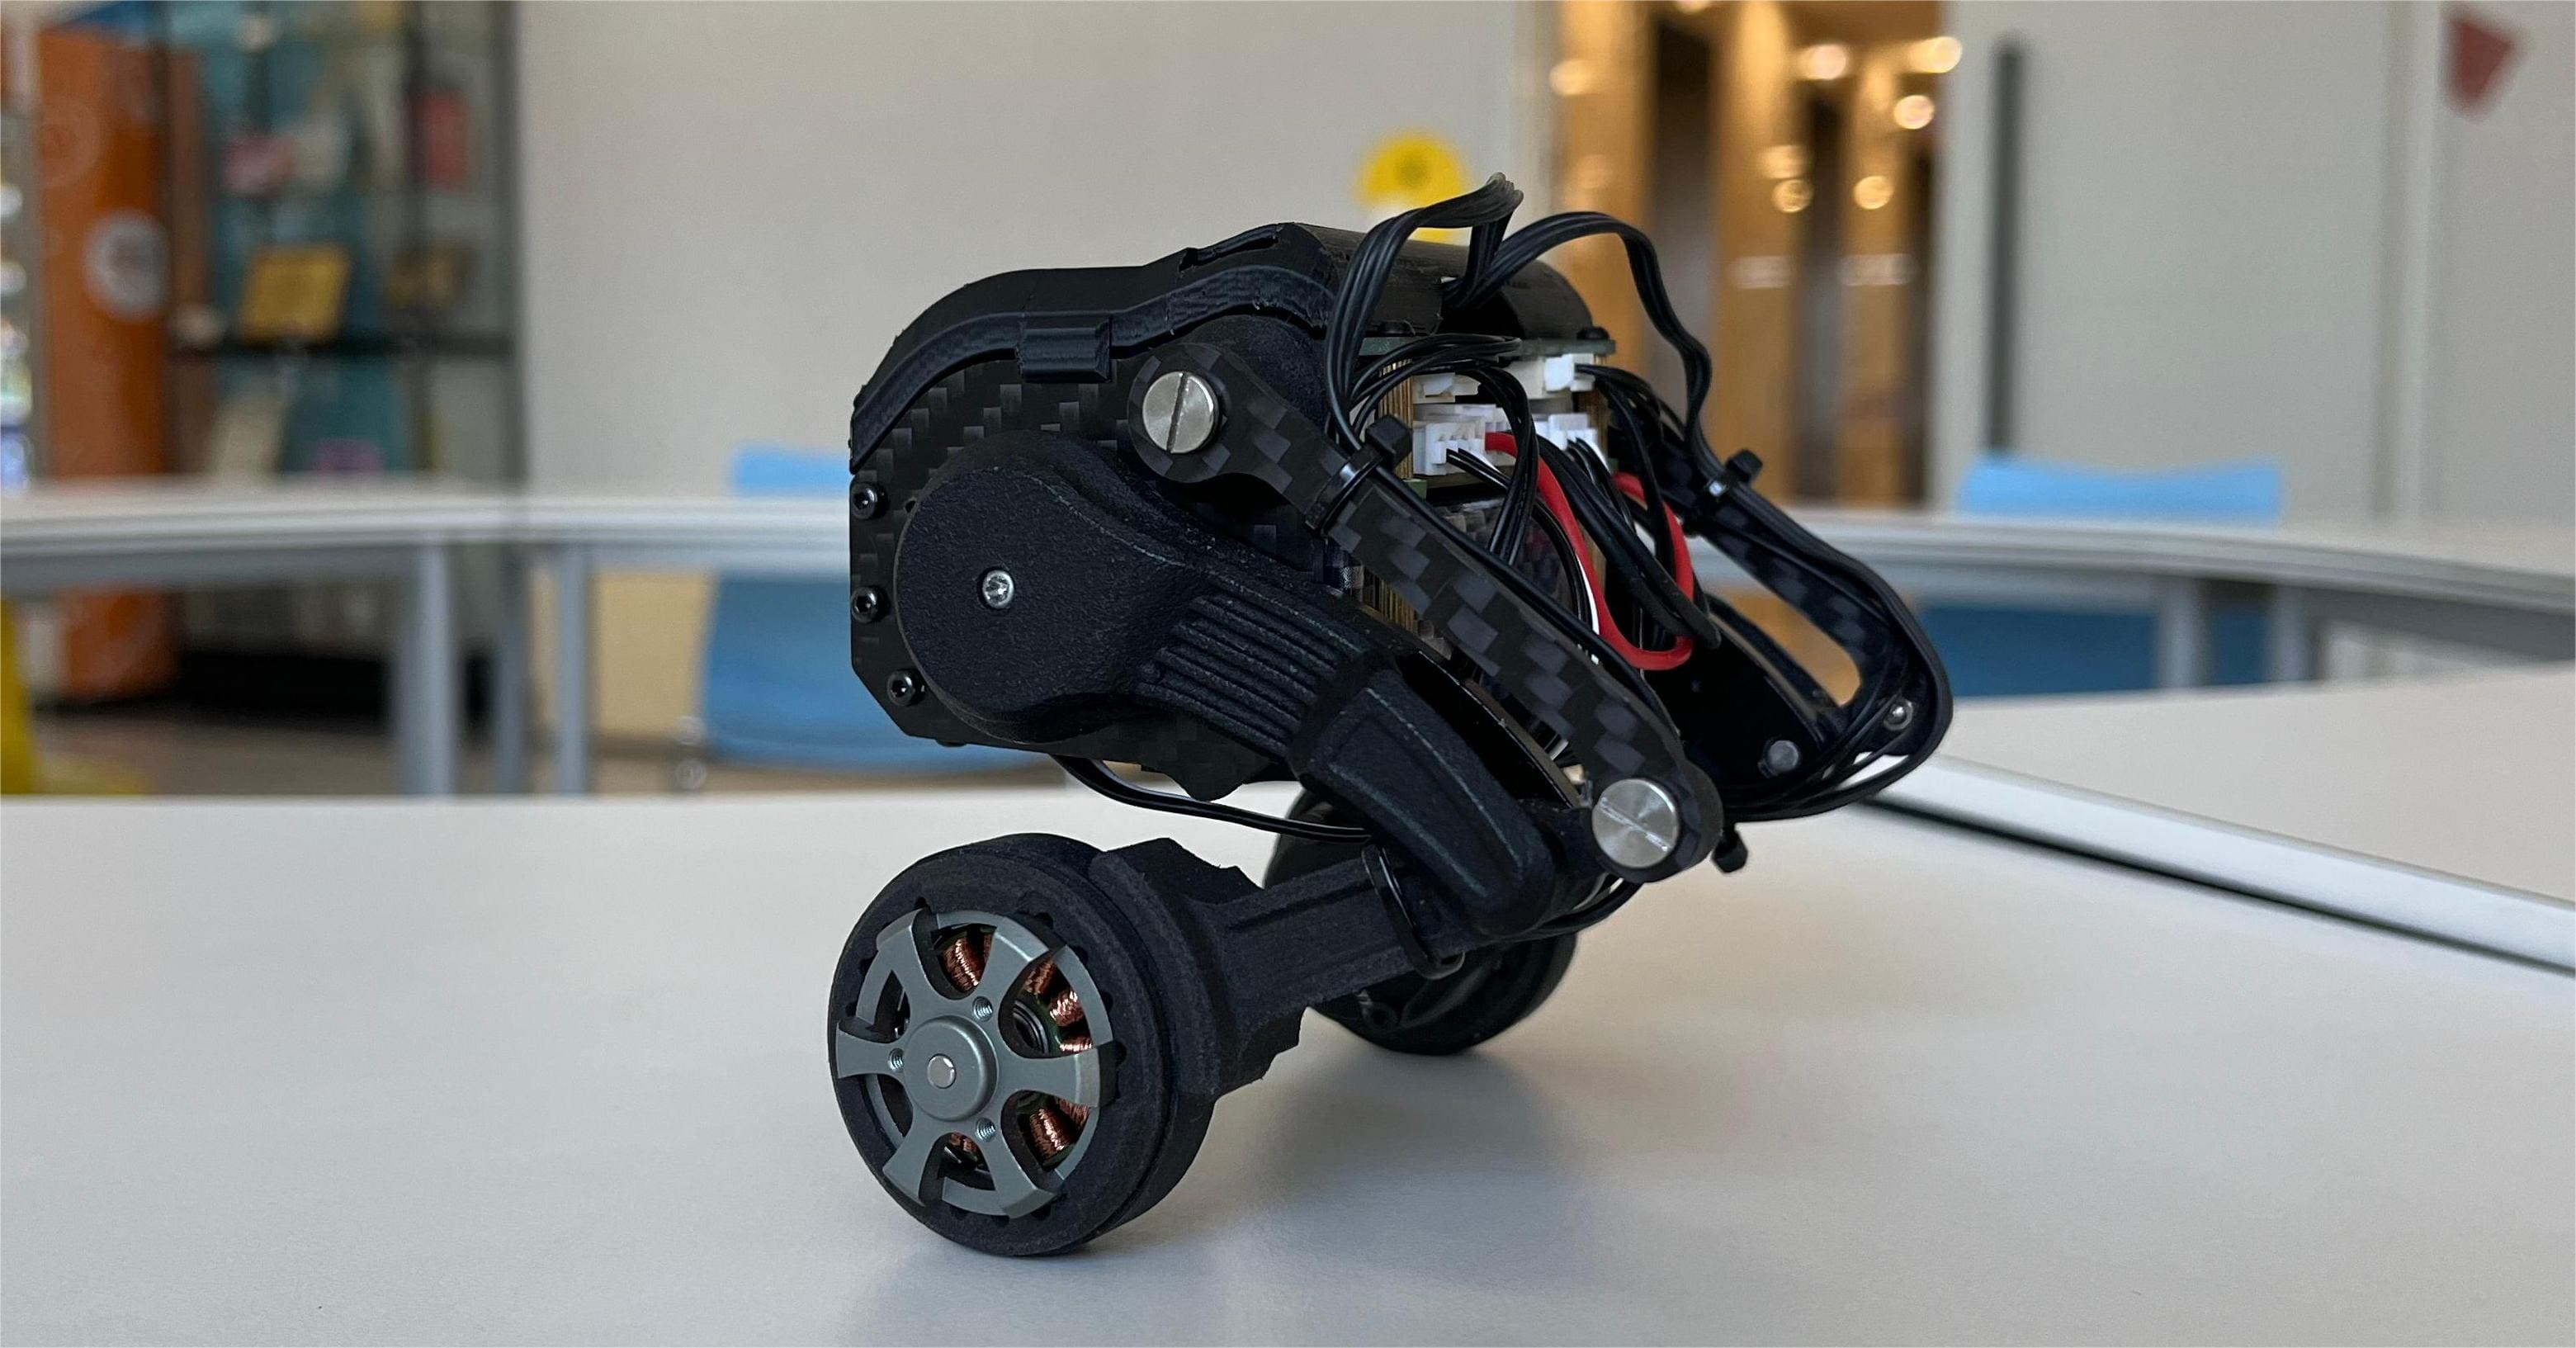
This is an ultra-compact desktop dual-wheel legged robot, integrating two-wheel self-balancing capabilities and leg movement. It provides a complete robotic implementation solution, including hardware design files, software code, and assembly guides, making it convenient for robotics enthusiasts to build and learn.
Comments

Rating:
No comments yet